Original 160 + Additional 240
동일 Simulator · Seed 반복
PERCEPTION → CONTROL
MotionCheck V2
Video-derived Reference · Torque Control · Encoder Feedback
Motion Compliance · Failure Analysis
MODEL / SIMULATORYOLO11s-pose · MuJoCo
2D Pose → Target Trajectory → Torque → Physics
Joint Encoder Feedback · 4-DOF · 500 Hz
Fixed Torso · 4-DOF Planar Arms · Recorded GPU Inference + Physics Simulation · Saved-result Playback
PD-only → FF+PD
Fresh Seeds · 20 Pairs · Matched PD Gains
Reference 관측 부족 · Unknown 8/8
Negative 5 · 검출 성공 없음
01 / PHYSICAL FEEDBACK
Controller Robustness
Disturbance Response · Parameter Variation
FF-only / PD-only / FF+PD
FRESH SEEDS 200–219 · 240 EPISODES
Joint Tracking Performance
Completion Criterion · 5 Target Windows · All 4 Joints ≤ 12° · Dwell Time ≥ 0.35 s / 평가 범위: 지정 구간의 Joint Tracking · 전신 동작·균형 평가 제외
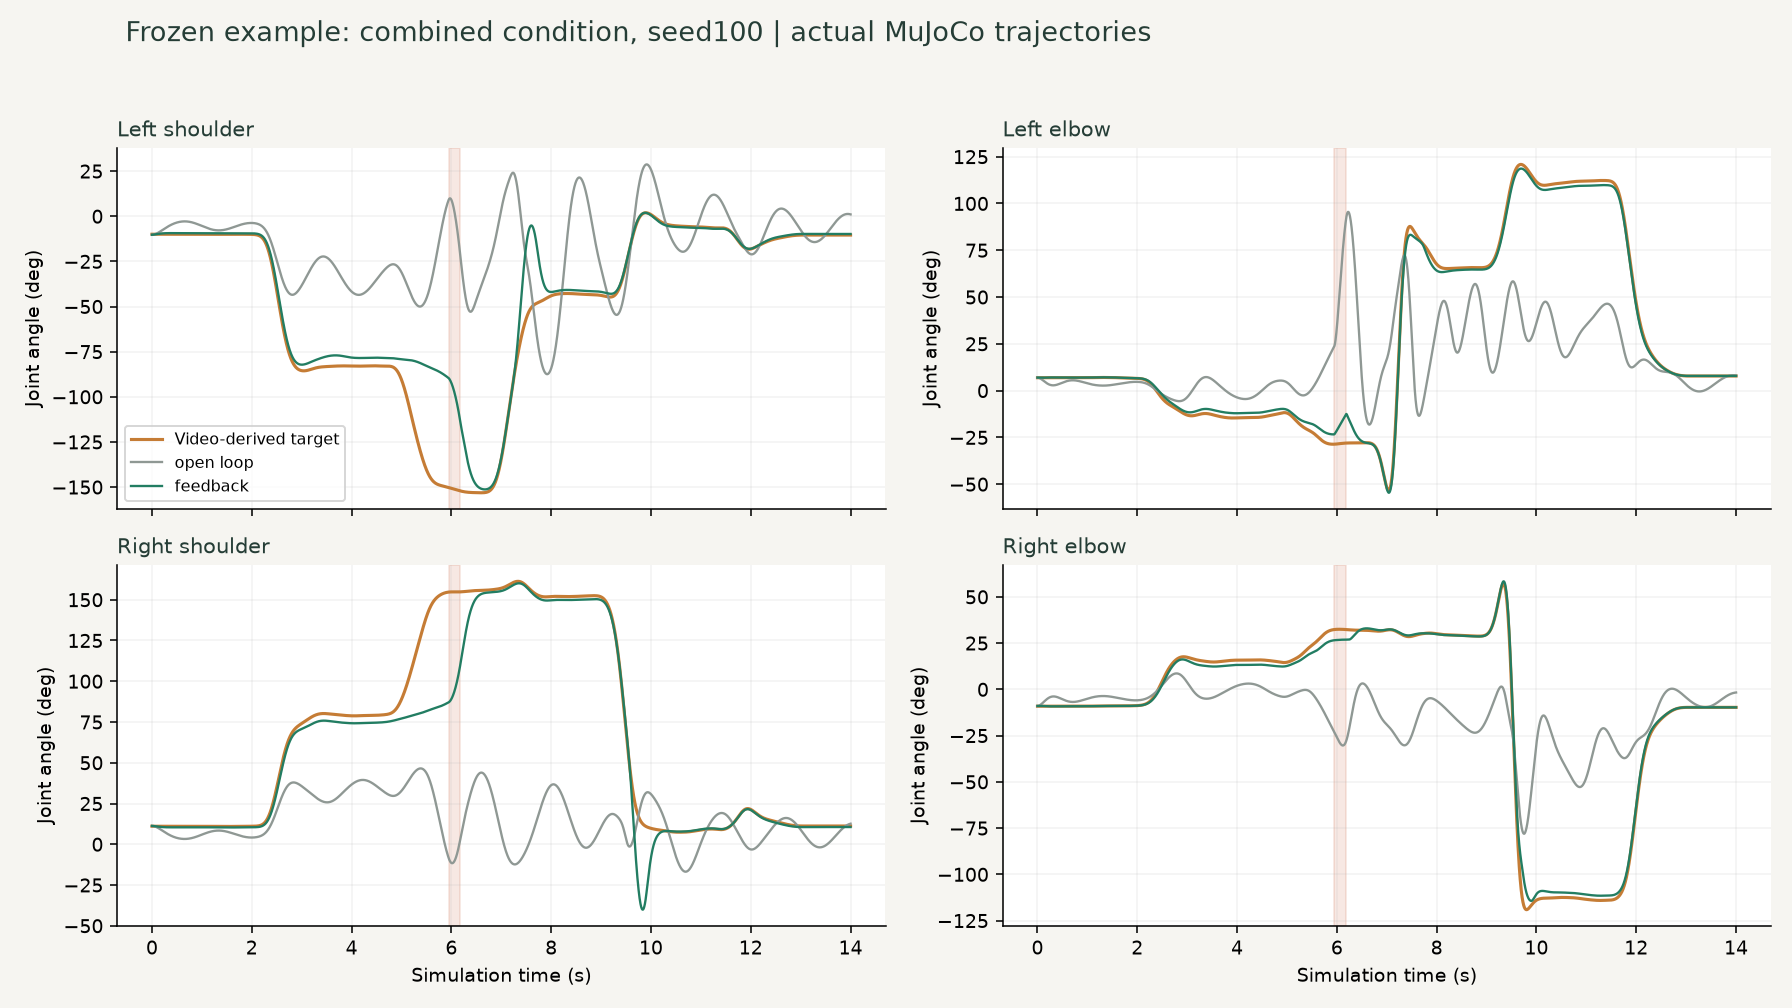
RECORDED PHYSICS / ORIGINAL SEED 100
Combined Perturbations · Failure CaseMuJoCo Rollout
Orange: Reference · Green: Simulated StateFF-only vs. FF+PD · Original Seed 100 / 위 표: 추가 실험 · Seeds 200–219
Joint Tracking · Error Analysis
FF+PD Completion · Original Seeds 100–119: 8/20 · Additional Seeds 200–219: 14/20 / 서로 다른 시드 집합 · 별도 집계
Pose Retargeting & Torque Control
Synthetic Video → 2D Pose → 4-DOF Arm Reference
MuJoCo · 500 Hz · Gravity / Inertia / Damping
Actuator Gain Reduction · External Torque Pulse
Feedback: Ideal Joint Encoders
Reference: Offline Video · 실시간 Visual Feedback 제외
Feedforward Ablation
FF-only: Nominal Instability
PD-only vs. FF+PD: Matched PD Gains · Fresh Seeds · Frozen Configuration
Combined Perturbations · Joint RMSE: 11.66° → 10.02°
Completion: 13/20 → 14/20 · 완료율 개선 근거 제한
02 / HUMAN MOTION · NEGATIVE TESTS
Motion Compliance
2 Arm Cycles · 5 Required Stages
Real Segments 4 · Edited Controls 4
Frozen Evaluation · Unknown 8/8
Pre-inference Labels · Positive 3 / Negative 5
기준 인물의 관절 관측 부족 · 모든 비교 보류
Negative Detection · 0/5
TWO CAPTURES / THREE VISIBLE PERFORMANCES
Reference & Candidate
ReferenceDVIDS · 15 fps
Candidate
0.00 s
Duration-normalized Playback · 화면용 시간 대응
판정 알고리즘 정렬과 별개 · Missing Keypoint 보간 없음
시각적 순서 주석 · Expert Grading 제외
Reference 품질과 별도 지표
Stage Evidence · 진단 전용 / Reference 전체 무효 시 Contract Met 제외
Semantic Contract · Post-hoc Analysis
Both Arms · Down → Overhead → Down → Overhead → Down
Wrist-height Predicates · Dwell Time
기존 평가 이후 동일 8개 재사용 · Independent Test 제외
| Case | Label | Data Type | Frozen Result | Post-hoc Repair |
|---|
Capture Sources 2 · Visible Performances 3 · 독립 인물 8명 아님
DVIDS 인물 2명 · 동일 촬영·지시 공유
평가 범위: Arm Sequence / 다리·운동 자세·Dance Quality 제외
03 / V1 → V2 · DEVELOPMENT REGRESSION
V1 Experiment ↗Stage Verification
Stage Order & Dwell Time
Stage 간 Sample 재사용 없음 · Missing Sample의 Dwell 기여 없음
Audit 한계: Sample 사이 짧은 가림의 누락 가능성
Reference Stage 확인 불가 시 Unknown
Detection & Abstention
Synthetic Middle Omission · 오류 검출
Real Floss의 생략·순서 오류 · Unknown 전환 · 검출 성공 아님
기존 개발 사례 21개 · Held-out Evaluation 제외
| Case | V1 | V2 | Interpretation |
|---|
REPRODUCIBLE PHYSICAL AI CASE STUDY
Validation Scope
Perception → Explicit Target → Physical Control → Quantitative Evaluation
전신 균형·접촉 · 3D Reconstruction · 실물 로봇 검증 제외